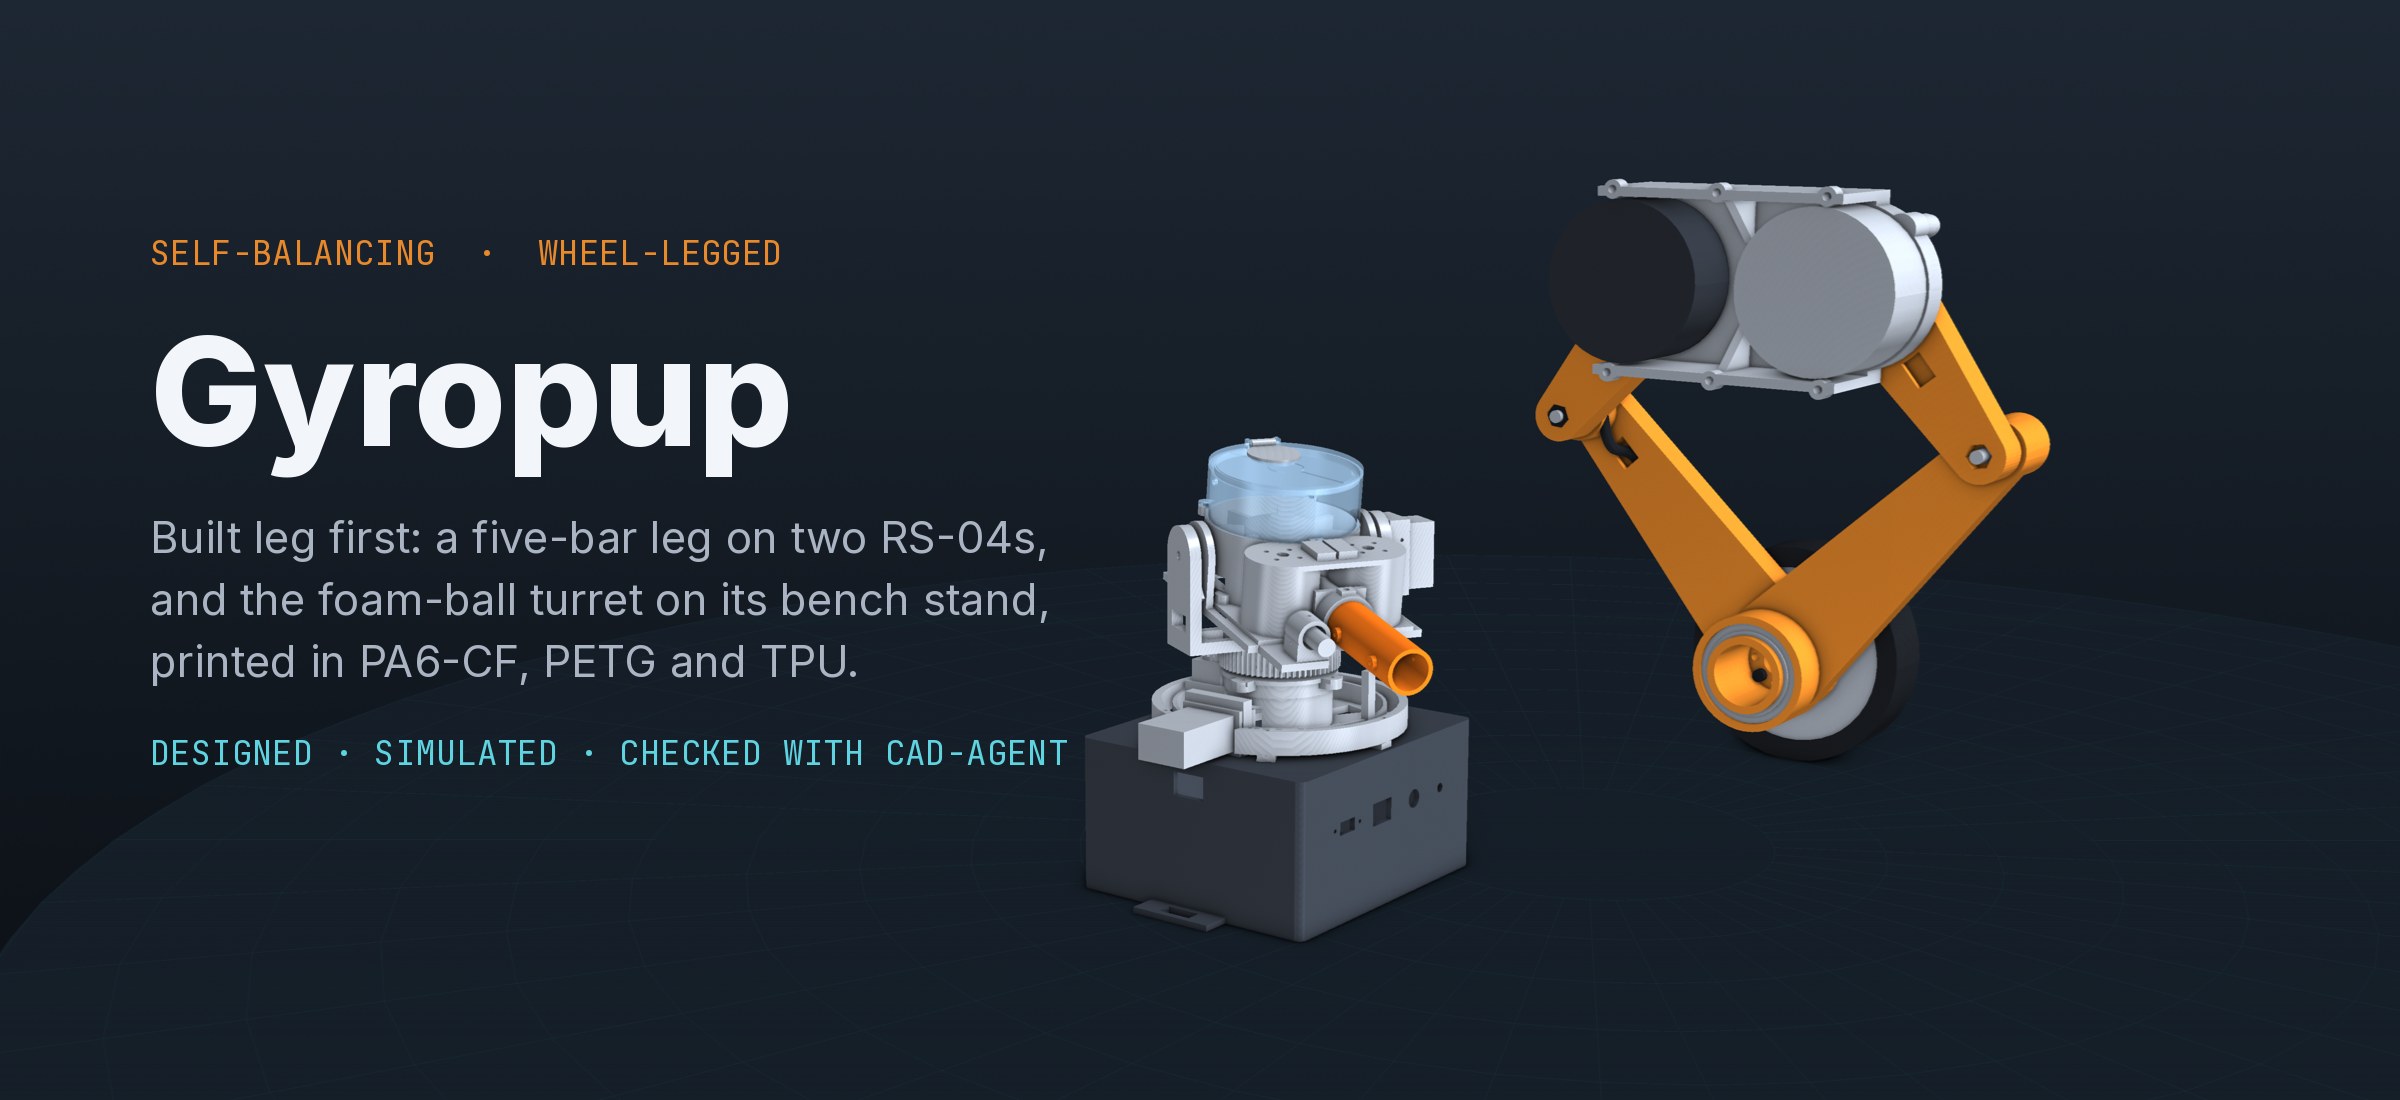
Gyropup
A friendly self-balancing wheel-legged robot that plays foam-ball target games with kids.
Gyropup balances on two hub-motor wheels and crouches, stands and jumps on two five-bar legs, each driven by two RobStride RS-04 actuators inside the body. A pan/tilt turret on top fires Rival-size foam balls at knock-down targets (always low, never above horizontal). Every custom part is 3D printed: structure in PA6-CF on a hardened nozzle, the rest in PETG and TPU. Bought parts are bearings, pins, screws and inserts from McMaster-Carr, the motors and the electronics.
One design, built in this order (decisions D36-D38 in docs/decisions.yaml):
- One leg on a vertical-rail test rig: a five-bar with both motors in its hip frame. CAD in
cad/fivebar.py, physics insim/leg_rig.py. - The turret on its own bench base (
cad/turret.py). - The body around two legs: the Orin compute, the battery and the electronics inside one printed shell, the lights on the hips beside the turret, the eyes on the face.
Status: leg v2 is in CAD and simulation; nothing is built yet. The old serial-leg robot (cad/build.py,
cad/leg.py, sim/model.py, the 3D game page) stays only until leg v2 is on the full robot.
Website & playground: gyropup.com. The same landing page,
simulator and engineering portal run locally: nvm use && npm ci && npm run dev.
Reviewed changes on main publish automatically through Cloudflare Pages.
Development, deployment and browser checks.
CAD dashboard: .venv/bin/cad-agent site --serve --port 8642 remains available
for the original local CAD workflow.
| Folder | What is in it |
|---|---|
cad/ |
The parts in CadQuery: the leg (fivebar.py, build_leg.py), the turret (turret.py), the interface standard (gmi.py, interfaces.json) |
sim/ |
MuJoCo: the single-leg rig (leg_rig.py); the old robot's balance controller and scenarios |
docs/ |
Requirements, decisions, milestones, the interface standard |
research/ |
Sourced research: comparable robots, actuators, wheels, power, sensors, the turret |
catalog/ |
The parts this robot uses, with specs, prices and sources (format); McMaster hardware in hardware.json |
designer/ |
The progress page and the 3D game page (Gyropup's voice and turret; the turret on the Orin AGX box, fired by hand, its mechanism laid open) |
tools/ |
The leg's geometry sweep, McMaster CAD downloads, the voice server |
The tooling that compared many designs and parts lives on in cad-agent as a
generic comparison framework; the version that was here is at the git tag explorer-snapshot-2026-10-26.
Licence: MIT, covering the code, CAD sources, generated models, docs and data in this repository.
Bought parts' vendor CAD (STEP files from McMaster-Carr, RobStride, Seeed and others) is not in the repository and is
not covered: references/vendor/**/SOURCE.txt records where each came from, and the build fetches them locally.
Product names and trademarks belong to their owners.